Home/Open Source

Open source

Today that's one thing: Zatsune's full CAD. Our code framework is in the lab — and we'll open it when it's ready, not before.

1 release outRaptCore in the lab

01 Available now

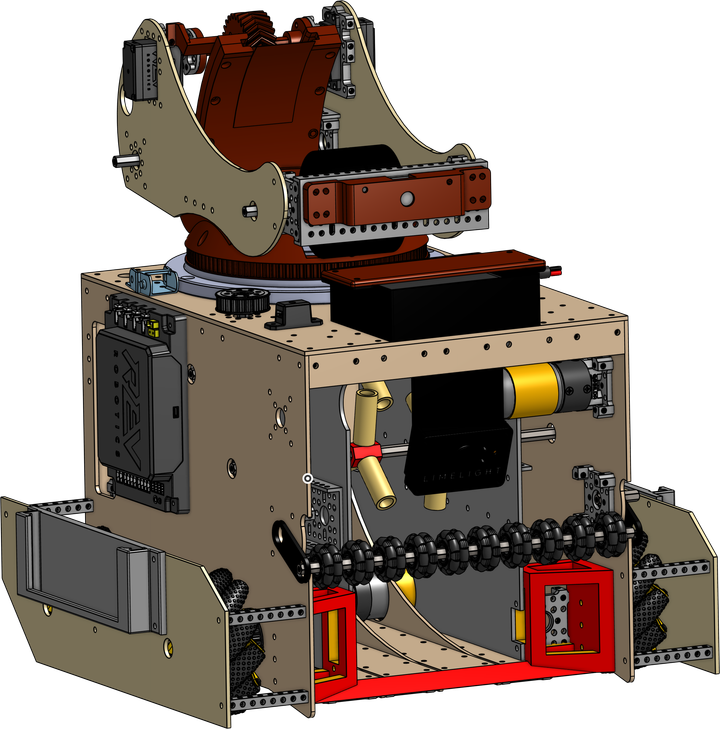
Zatsune CAD render
FIG. 25-26ZATSUNE
↔ Drag to tiltOnshape
Public

Zatsune CAD

The complete 2025–26 robot in Onshape — the robot that won the Design Award at the SC State Championship. Copy it, measure it, borrow from it.

Includes
Turret, flywheel & hood, intake, transfer, drivetrain
Format
Onshape document — open in your browser, copy to your workspace
Frame
Laser-cut wood base with belted mecanum

02 In the lab

Coming soon.Release: TBD.

One framework any FTC team can fork once and reuse every season — with RaptPath and RaptDash inside, and each usable on its own. It's being built, measured, and tested now. Here's a look through the door.

In the labRelease TBD

THE FRAMEWORKRaptCore

The robot code you'd otherwise rewrite every September — drive, localization, subsystems, match-day safety — built once.

  • Any chassis, any localizer
  • A tuning ladder that measures your robot for you
1,158
tests so far
Planned license MIT
In the labRelease TBD

LIBRARY · IN RAPTCORE + STANDALONERaptPath

Path following that tunes itself in simulation first — then fires while it drives.

  • A digital twin fitted from your robot's own logs
  • Shoot-on-the-move aiming
SIM
before the field
Planned license MIT
In the labRelease TBD

LIBRARY · IN RAPTCORE + STANDALONERaptDash

Blurred preview of RaptDash
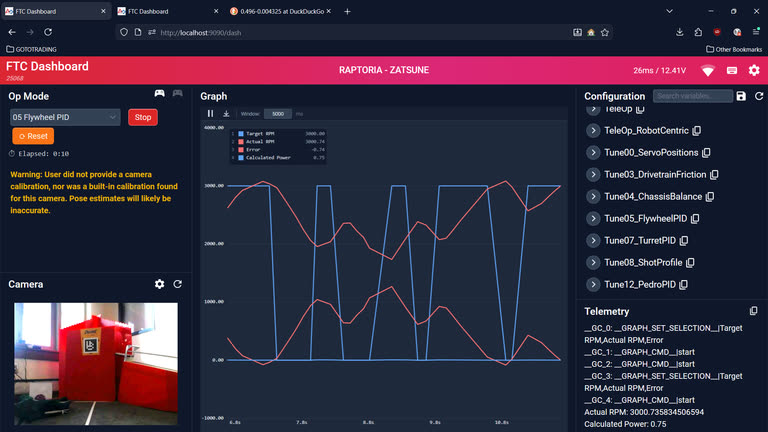
  • Live tuning from a browser
  • Draw paths on the field and push them to the robot
In the labRelease TBD

TOOL · IN RAPTCOREWaypointer

Drive the robot. Drop waypoints as you go. Export a competition-ready autonomous.

  • Records while you drive in TeleOp
A · LB
drop · export
Planned license MIT

Want to know when it drops?

We'll announce every release on Instagram and GitHub first.